Shuaijun Wang
Xiaomi Robotics · Senior Algorithm Engineer · Dexterous Manipulation Technical Lead

“Nothing unique about human intelligence compared to AI.”
Hello, I am Shuaijun Wang, currently serving as Technical Lead of Dexterous Manipulation in the Robotics Department at Xiaomi Technology. I received my Ph.D. degree from the Robotics Institute, National Key Laboratory of Harbin Institute of Technology, under the supervision of Professor Lining Sun. I obtained my M.S. degree from Harbin Institute of Technology(Shenzhen) under the supervision of Professor Xin Wang, and my B.S. degree from Northeast Forestry University as an Outstanding Graduate.
Between 2019 and 2021, I conducted research as a visiting scholar at the School of Informatics, Robotics Center of the University of Edinburgh, working with Professor Zhibin(Alex) Li. From March 2022 to December 2022, I collaborated remotely with Professor Qiang Li at the Robotics Center of the University of Bielefeld in Germany. In 2022-2023, I worked as a research intern at Tencent Robotics X Laboratory.
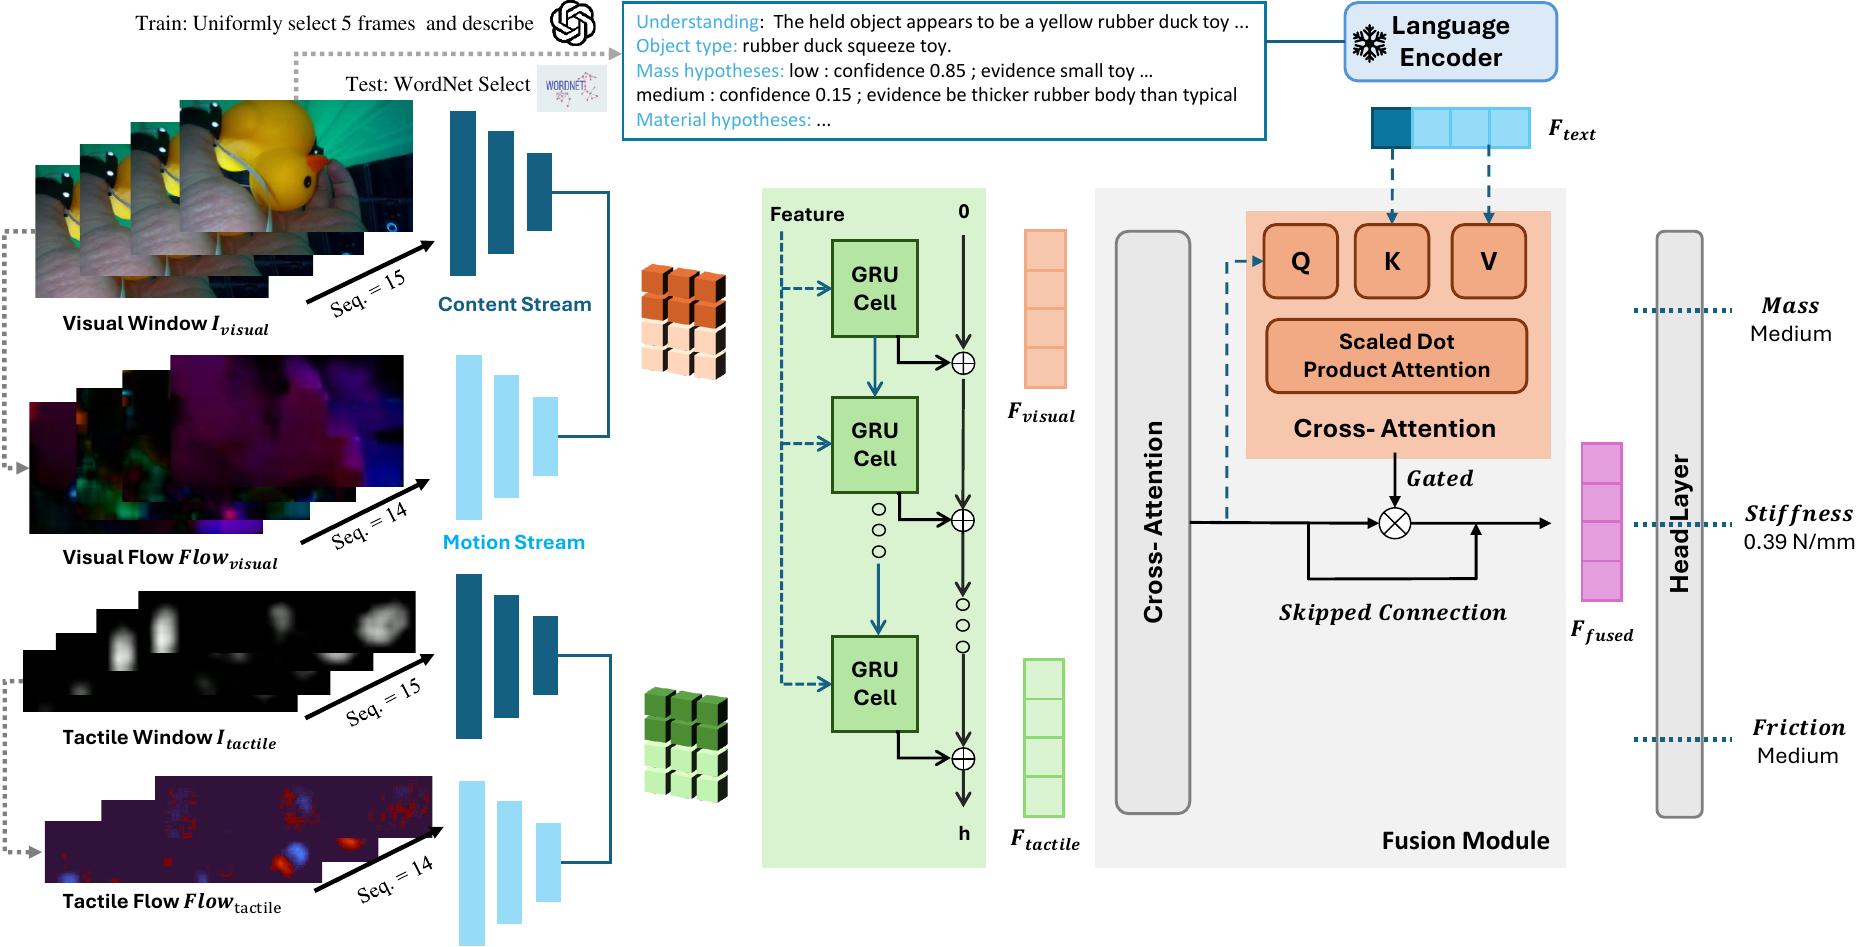
My research focuses on universal and dexterous grasping and manipulation of humanoid robots, as well as embodied AI. Recently, I have been developing foundation models for dexterous manipulation.
Research Interests
- Dexterous Manipulation and Grasping
- Tactile Perception and Feedback
- Reinforcement Learning and Imitation Learning
- Full-self Manipulation(FSM)
- Embodied Intelligence
news
| Oct 13, 2026 | One paper has been accepted to IEEE Robotics and Automation Letters (RA-L)! |
|---|---|
| Mar 29, 2026 | Our work TacRefineNet is featured in Xiaomi Group’s FY2025 annual results presentation materials (PDF). |
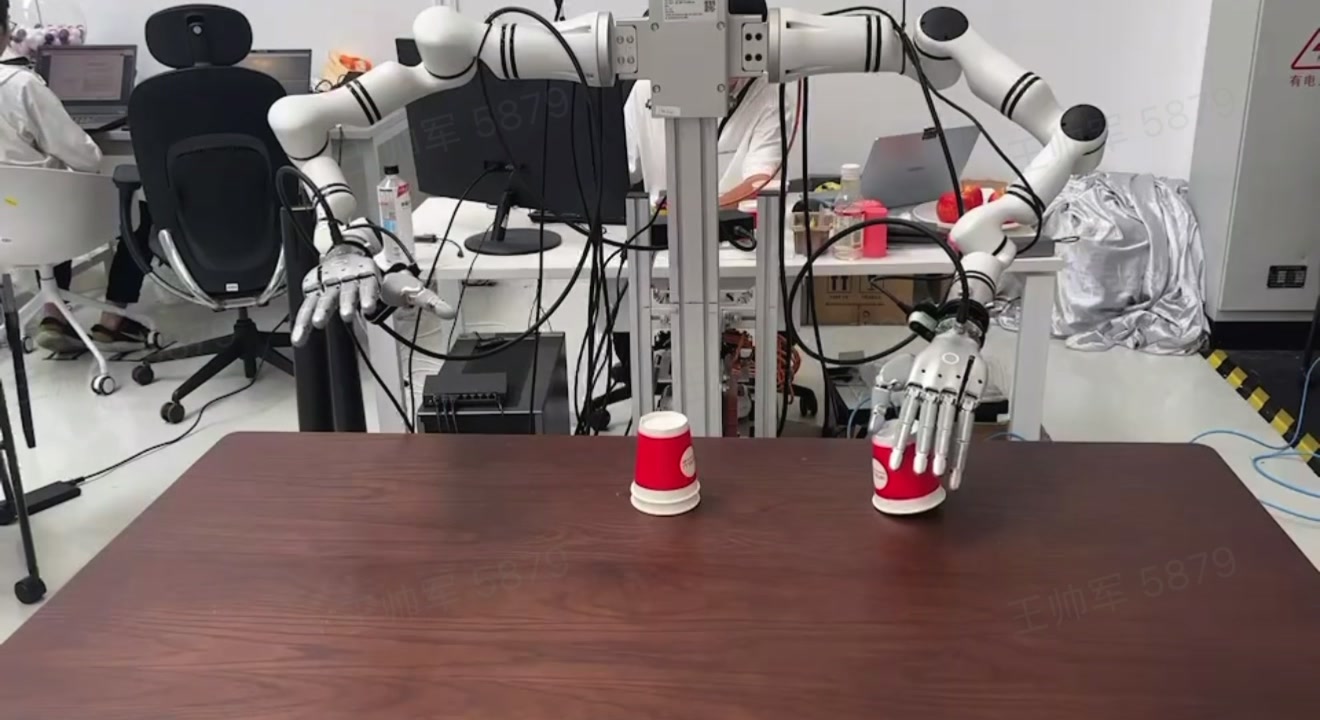
| Oct 15, 2025 | Our paper “HD2Handover: Human-like Dynamic Dexterous Bimanual Handover using RGB-only Perception” has been accepted to the IROS 2025 Workshop on Bimanual Manipulation: Advancing Human-Humanoid Interaction and Collaboration. |
| Jul 01, 2024 | Joined Xiaomi Robotics Department as a Senior Algorithm Engineer, building from 0-1 and serving as Technical Lead of the Dexterous Manipulation Team! 🎉 |
| May 01, 2024 | Successfully earned Ph.D. in Robotic Learning from Harbin Institute of Technology! 🎓 |
| Dec 01, 2023 | Invited talk at Shenzhen Technology University on “Embodied Intelligence Methods for General-Purpose Robotic Grasping and Manipulation”.(Received Assistant Professor invitation) |
| Jun 01, 2023 | Completed a research internship at Tencent Robotics X Lab (Dec. 2022 – Jun. 2023), where an existing fingertip tactile-based in-hand manipulation algorithm was reproduced and successfully transferred to Tencent’s next-generation dexterous hand platform, receiving broad media coverage. |
| Feb 16, 2022 | Paper “Learning Adaptive Grasping From Human Demonstrations” published in IEEE/ASME Transactions on Mechatronics (SCI Q1 Top journal in Robotics)! 🏆 |